To evaluate the population variation in head-to-helmet contact forces in helmet users.
- Research Assistant & Co-author
- Northeastern University Center for STEM Education / Young Scholars’ Program
- June 2023 – August 2023
- Force sensitive resistors, Arduino Mega, Digital force gauge, Caliper stand, Custom chinstrap tension gauges
- University research group, Young Scholars’ Program
- Research · Experimental Mechanics · Biomedical Engineering · Finite Element Analysis
Specifications
- Measurement and Assessment of Head-to-Helmet Contact Forces
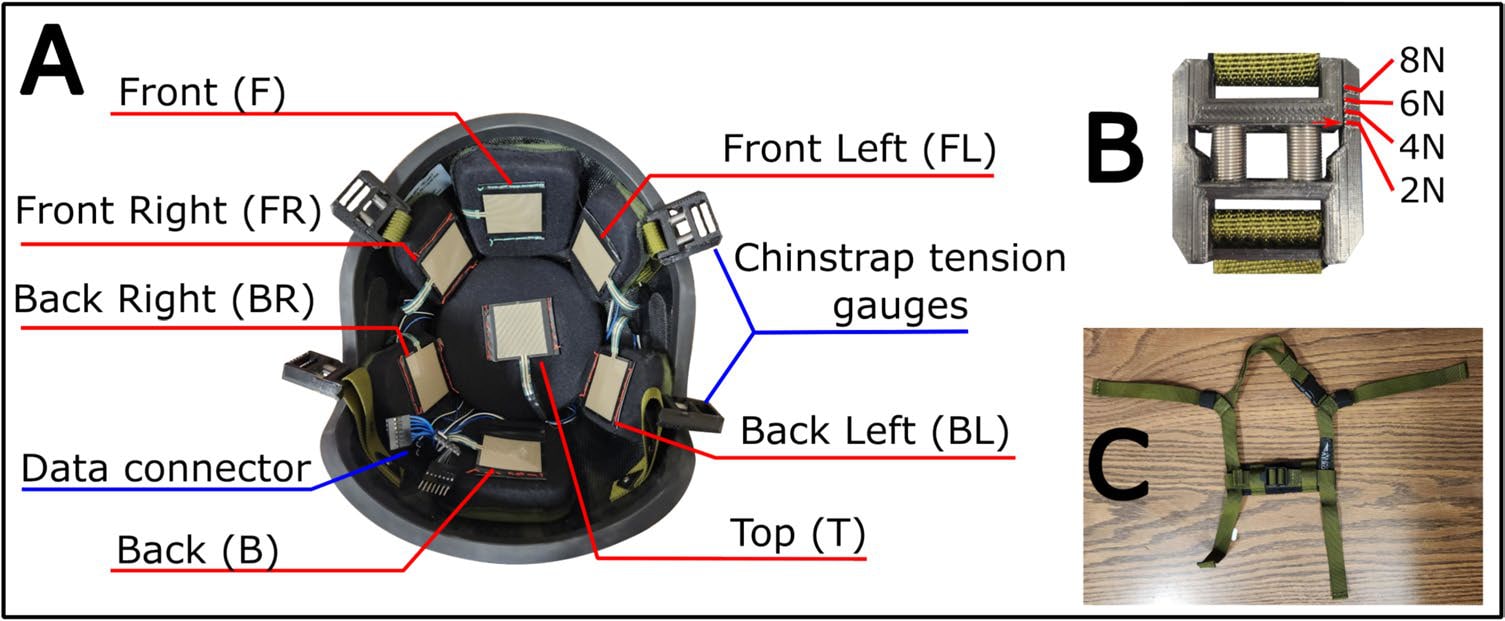
- Four sizes of Kevlar composite helmet, seven interior pads each
- A force sensitive resistor on each pad; custom chinstrap tension gauges
- 89 (25 female, 64 male)
- Methodology, validation, investigation
Focus areas
- Methodology
- Validation
- Investigation
Measurement system
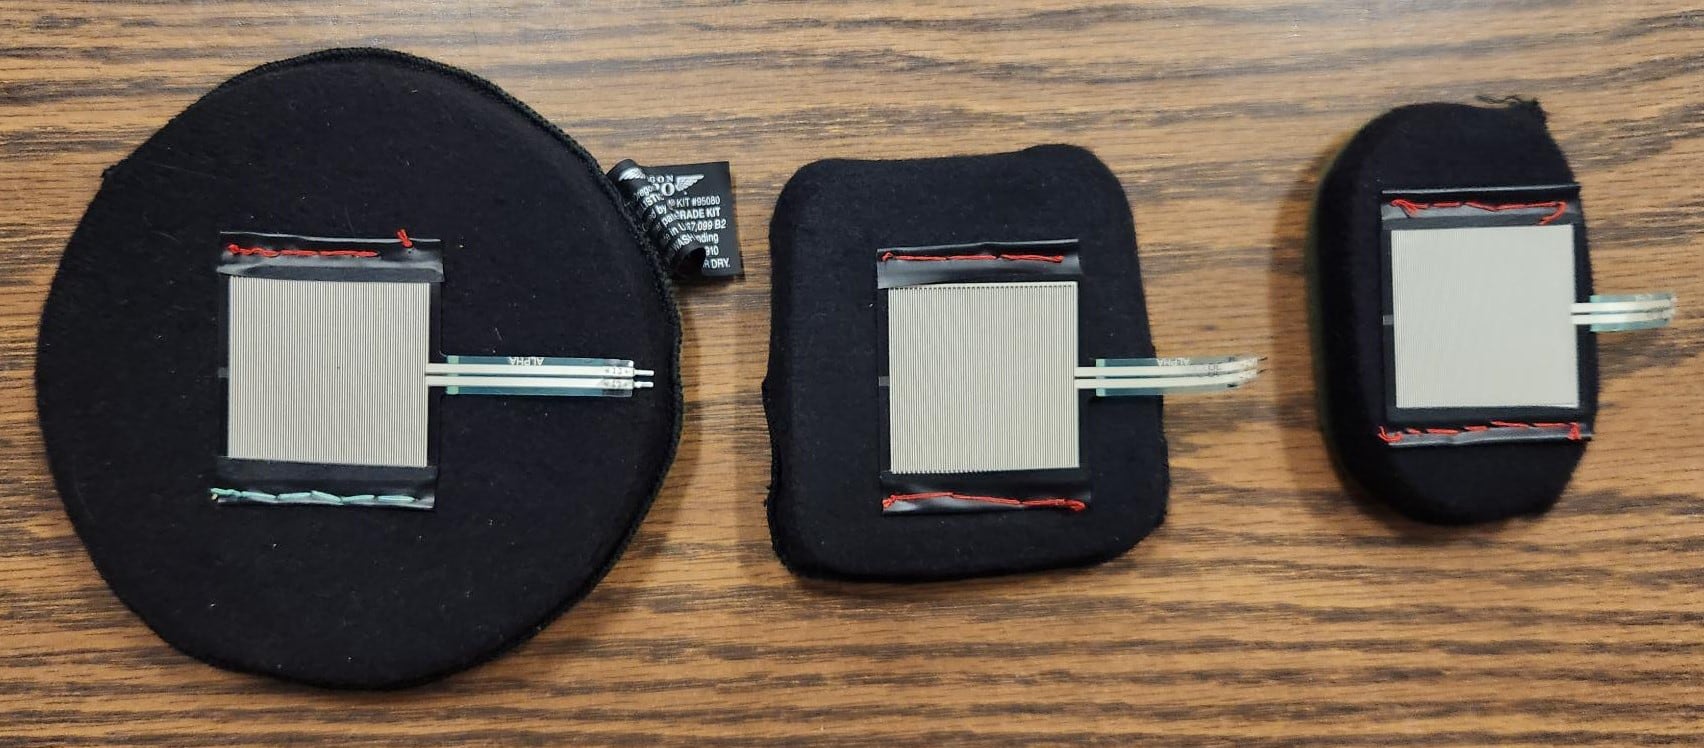
A force sensitive resistor (FSR) (Adafruit Industries, LLC. New York, NY) was installed on each pad. To mount each FSR, a flexible rim was created around the perimeter of the sensor using electrical tape. The rim was sewn onto the cloth exterior of the padding, which allowed the sensors to flex and conform to the shape of the pad. Measurements were recorded using an Arduino Mega microcontroller.
To measure the tension in the chinstrap, a custom mechanical force gauge was developed which replaced the original adjustment buckles in the chinstrap.
Calibration
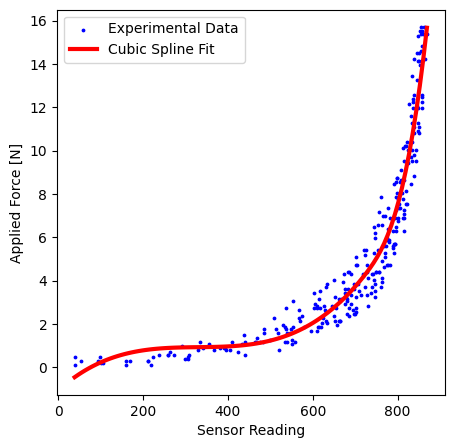
Because flexure in the FSR was observed to change the measured force value, the pressure measurement on the surface of the pad was calibrated with the FSR and pad installed in the helmet.
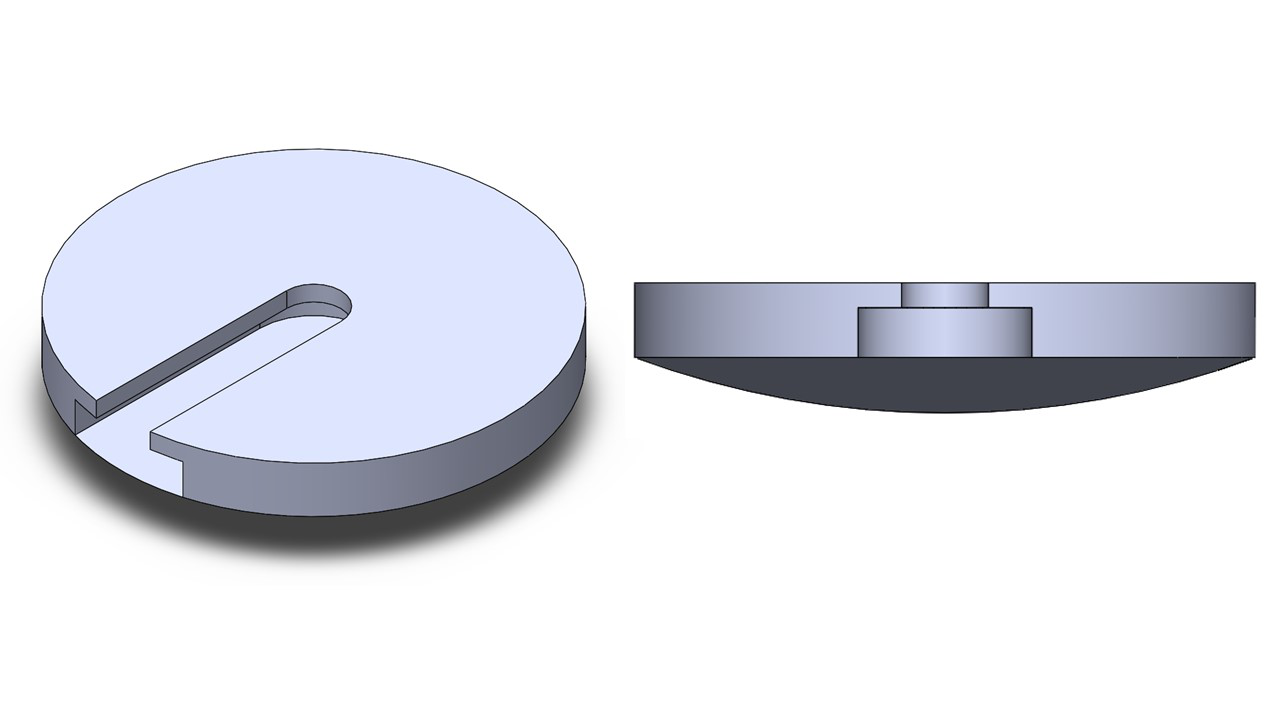
A digital force gauge (Imada, Inc., Northbrook, IL) was used to measure the force applied to the FSR. A curved force applicator was fitted to the force gauge to emulate the curvature of the head. The force gauge was mounted on a caliper stand (Mitutoyo America Corp., Holyoke, MA) which was used to apply variable compression to the padding. A cubic spline was found to have the lowest RMS error when fitting the data so was used to relate the FSR analog value to sensor force.
Results
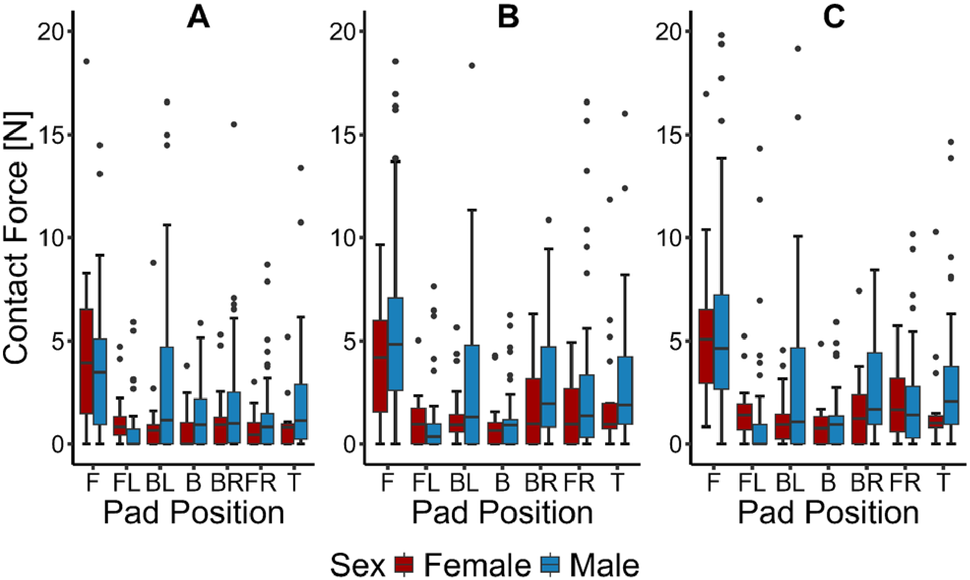
The majority of forces measured on any individual pad were between 0 and 5 N. However, some users exhibited pressure points with forces as high as 30 N. The contact force distribution is non-uniform across the interior of the helmet, with the largest force concentrated at the front.
Publication
Jennings, T., Tillman, A., Mukasa, D., Marchev, M., Müftü, S., Amini, R. Measurement and Assessment of Head-to-Helmet Contact Forces. Ann Biomed Eng 53, 946–955 (2025). https://doi.org/10.1007/s10439-025-03677-3
Author contributions: Michael Marchev contributed toward methodology, validation, and investigation.
Text and figures on this page are from the article and its supplementary material, published open access under a Creative Commons Attribution 4.0 International License (https://creativecommons.org/licenses/by/4.0/). Figures were resized.
Next project
luX-RayLet’s talk.
Open to co-op, internship and project conversations in mechanical design, product development and R&D.