Skip to content
04

Prototype completeDecember 2024 – April 2025

Generate Product Development Studio logo

An assistive mobility device that not only functions as a walker and rollator but also provides powered assistance to help users safely and comfortably sit down and stand up.

Role
Mechanical Engineer
Organization
Generate Product Development Studio
Timeline
December 2024 – April 2025
Tools
Onshape, FDM (PLA), SLA (Grey Pro), Shop tools
Team
Mechanical and electrical sub-teams at Generate
Project type
Human-Centered Design · Product Development · Mechanisms · Prototyping · Electromechanical Integration
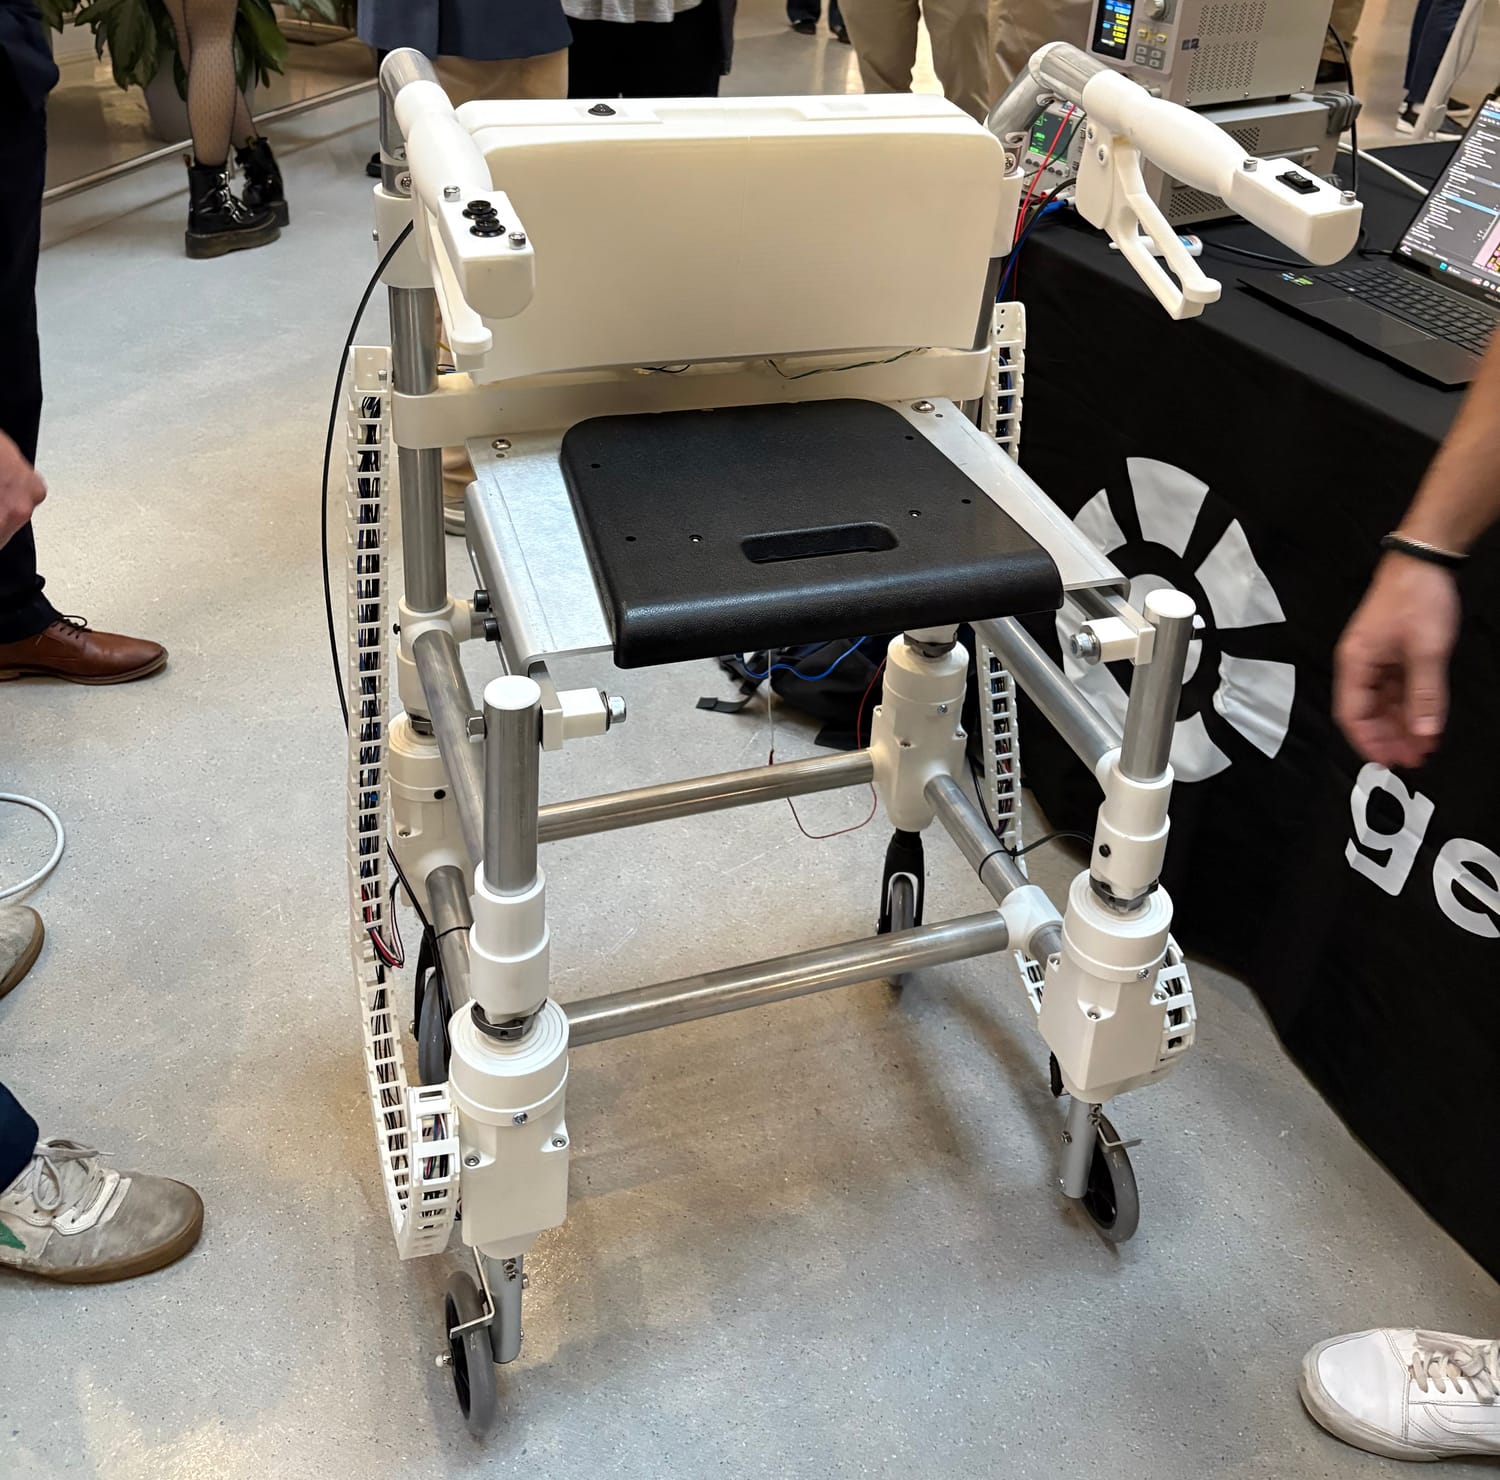
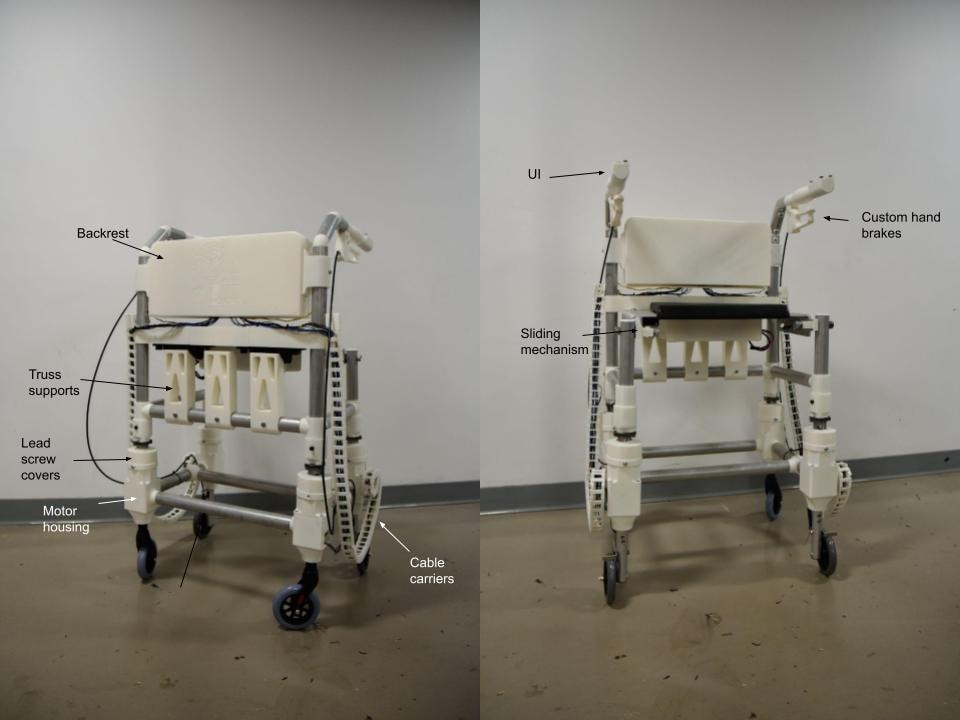
The white walker prototype on display: aluminium tube frame, printed joints, a black seat, a backrest housing, handles with controls, and cable carriers running down each side to the powered legs.
04.0 — DEVICEThe finished prototype, with powered legs, integrated seat and cable carriers on each side.

Specifications

Device
Walker and rollator with powered assistance to sit down and stand up
Users
Elderly individuals with difficulty transitioning between sitting and standing
Weight
≈ 50 lb target, met
Actuation
Four stepper motors, 12 in × 20 mm hardened steel ball screws
Frame
1-1/2 in aluminum conduit, FDM PLA connectors
My scope
Framing connections, battery box, mech/elec integration
Prototyping
FDM PLA and SLA Grey Pro, iterated in Onshape

Focus areas

  • Mechanisms
  • Human factors
  • Integration
  • Weight
  • Fast iteration
  • Medical / Human-Centered Design
  • Product Development
01

System overview

Two photos of the Uplift walker prototype, from the back and the front, labelled: backrest, truss supports, lead screw covers, motor housing, cable carriers, UI, custom hand brakes and sliding mechanism.
04.1 — SYSTEM OVERVIEWSystem Overview
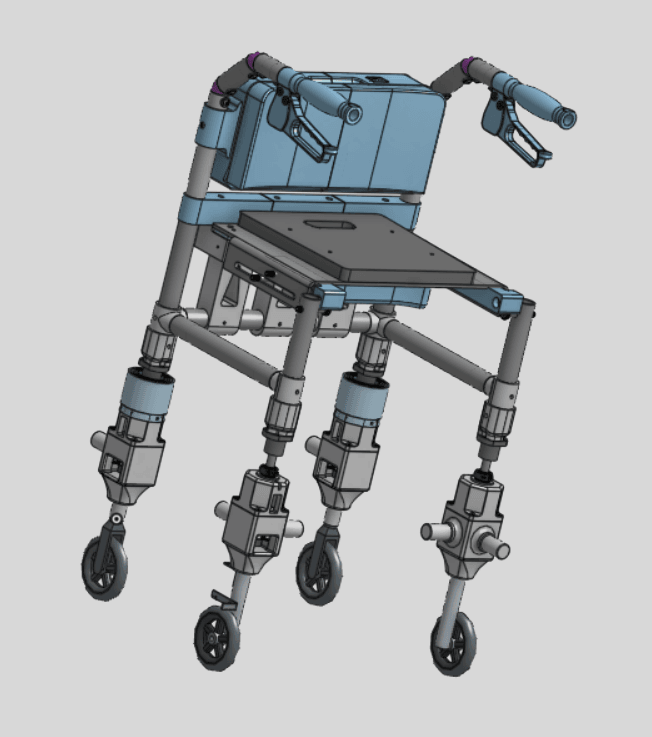
CAD assembly of the walker: tube frame, seat, backrest housing and handles above four powered legs on caster wheels.
04.2 — ASSEMBLYFull assembly: frame, seat, backrest housing, handles and four powered legs.
02

Framing connections

I led iterative development of the conduit linkages in Onshape, printed in FDM PLA and SLA Grey Pro.

All parts shown in framing were FDM 3D printed out of PLA with 20% infill using Grid or Gyroid pattern.
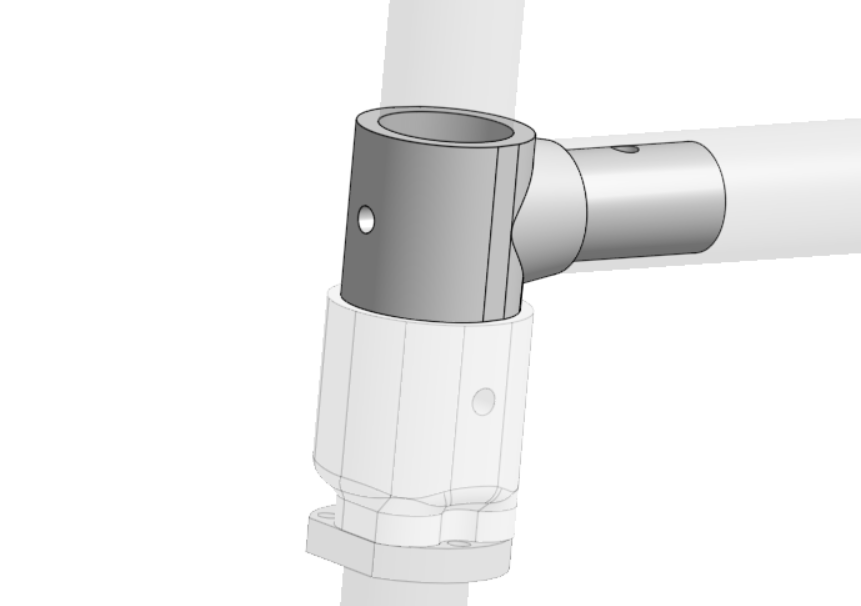
CAD of a grey 90-degree connector: a vertical sleeve around one conduit, with a horizontal insert pressed into a second conduit, above a motor housing.
04.3 — SLIDING CONDUIT CONNECTOR90-Degree Sliding Conduit Connector. The goal of this piece was to keep the front and back of the walker horizontally constrained while still allowing for relative vertical motion.
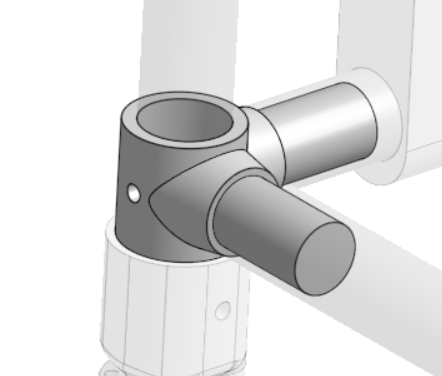
CAD of a grey static connector with two horizontal arms, joining a vertical conduit to two horizontal conduits.
04.4 — STATIC CONDUIT CONNECTOR90-Degree Static Conduit Connector. There was also a non-sliding version of this piece with two horizontal connections on the other end of the walker.
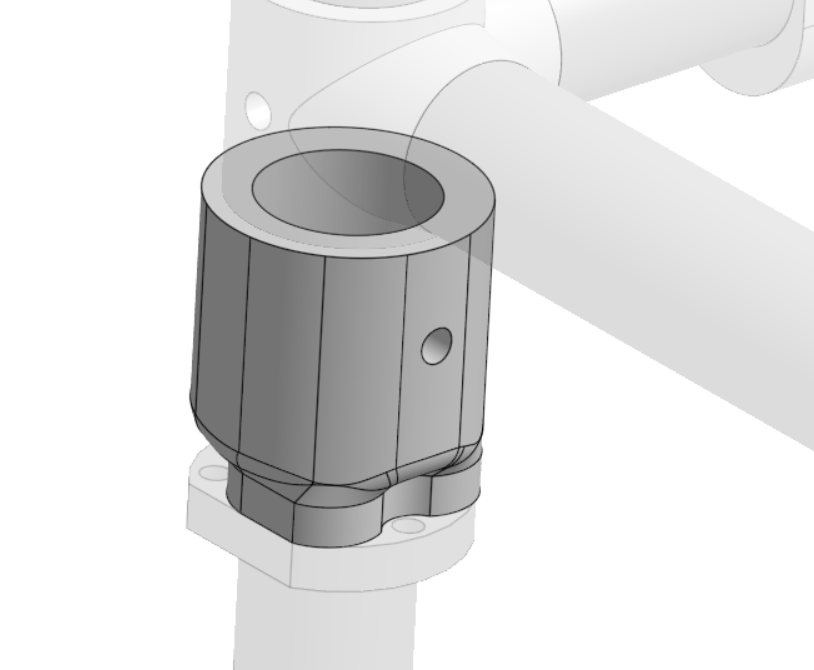
CAD of a grey cylindrical connector around the top of a conduit, its flanged base fastened to a ball nut.
04.5 — CONDUIT-BALL NUT CONNECTORConduit-Ball Nut Connector. With relative motion constrained as necessary, the top of the frame needed to be mated to the legs/lead screws; this piece is screwed to the ball nuts via heat-set insert and press fit around the top of the frame's conduit.
03

Battery box

I coordinated with the electrical sub-team to integrate the motors, house the electronics and protect the battery.

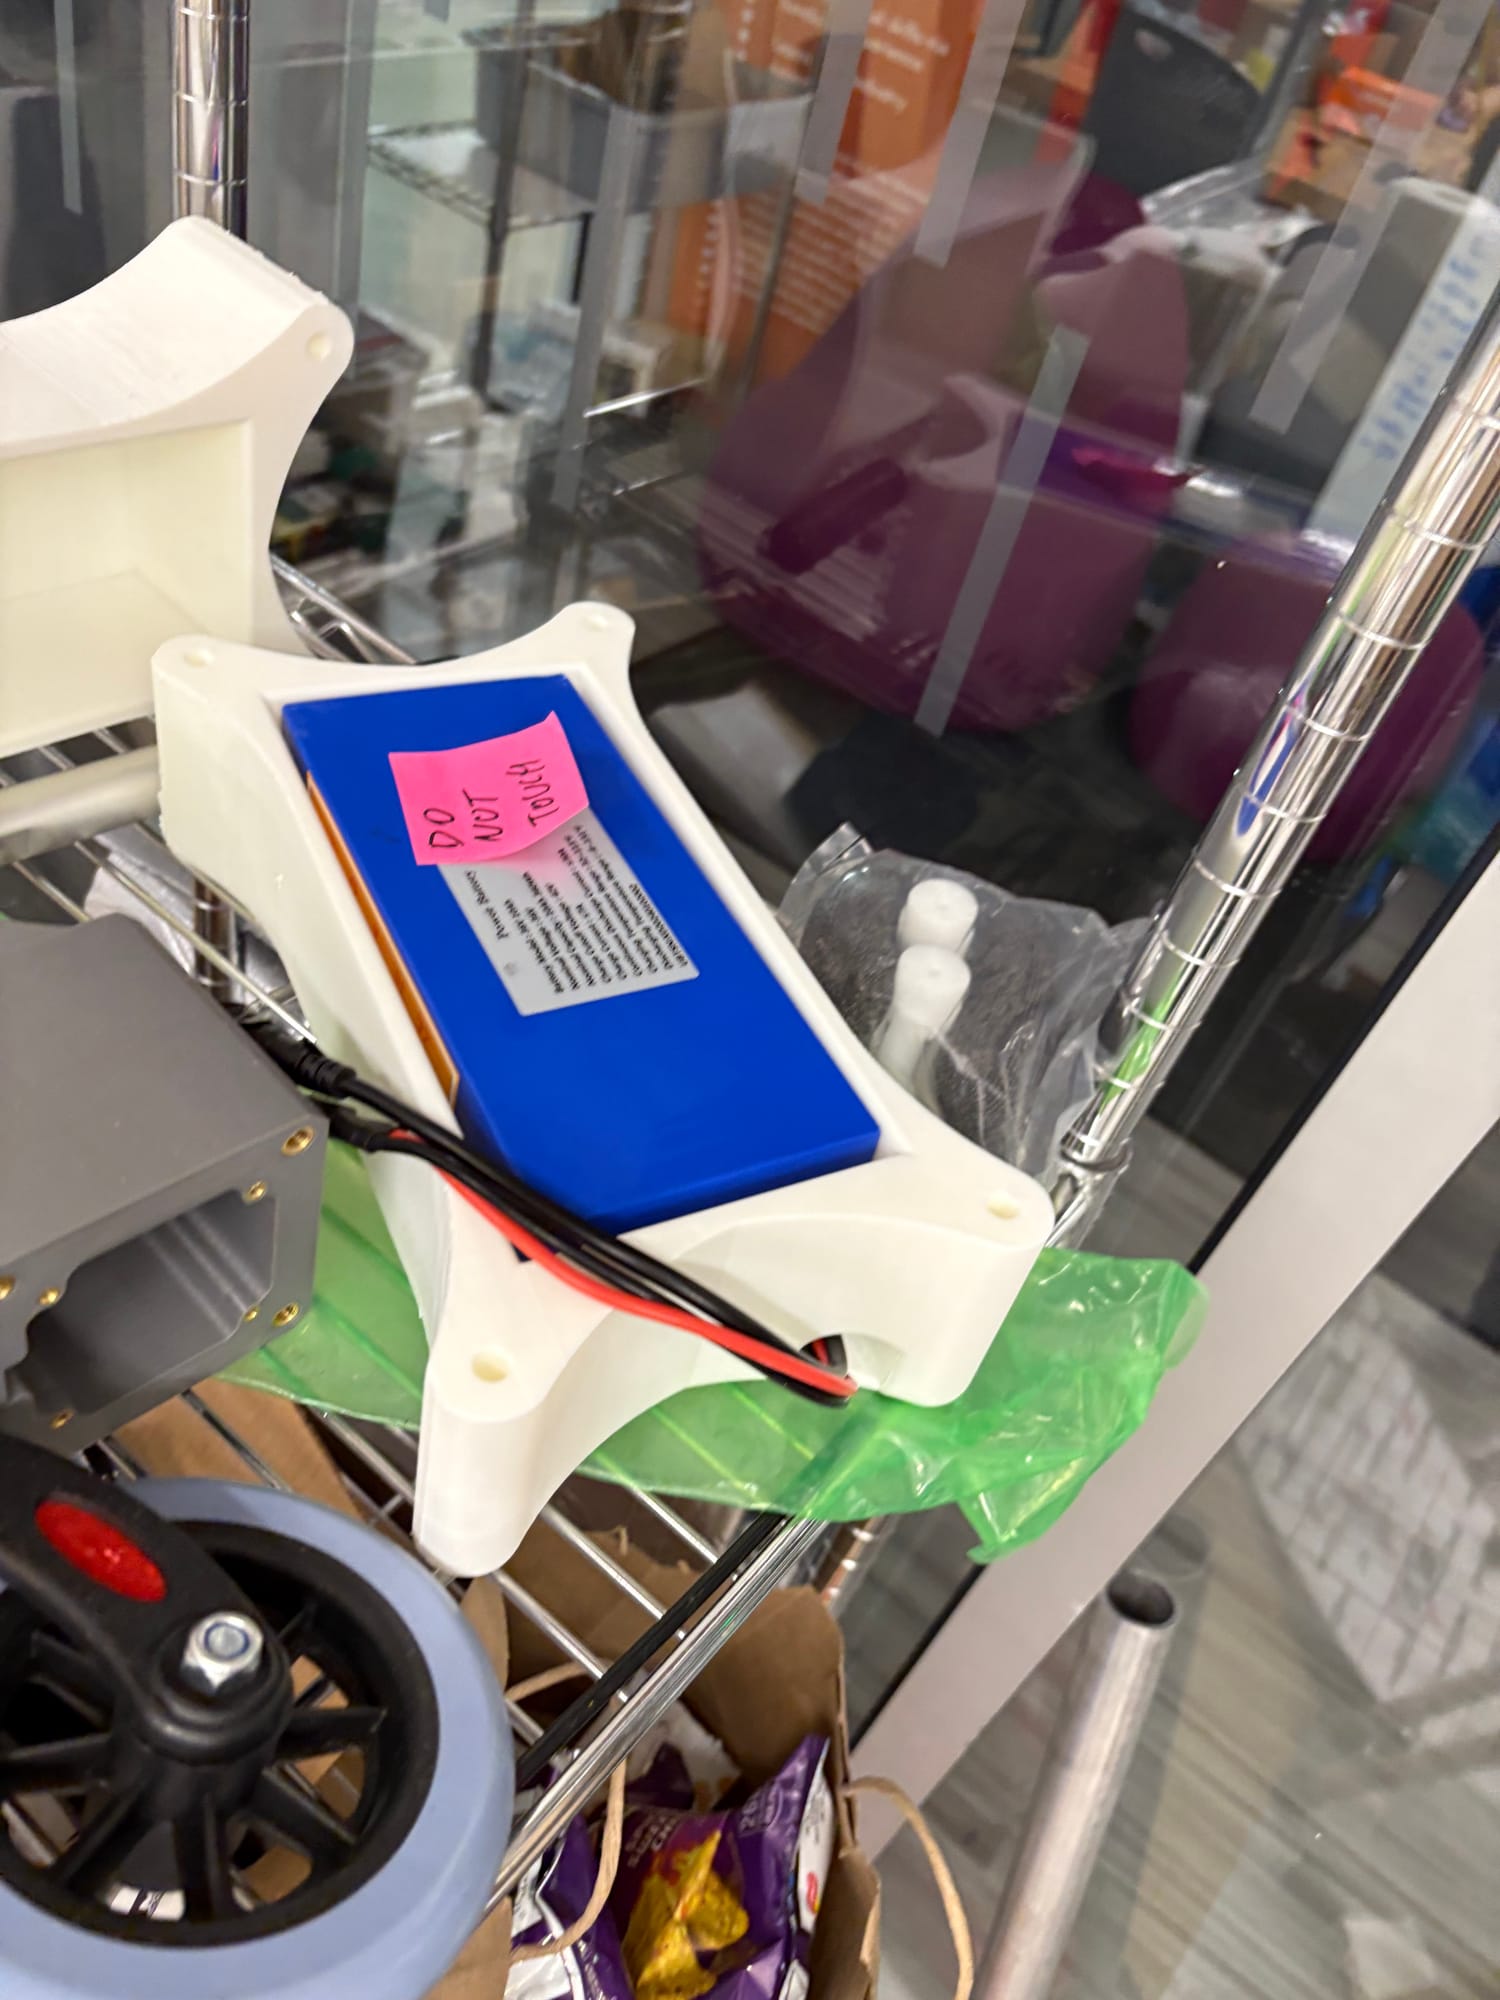
A housing was designed that snugly fits the battery underneath the seat while still allowing cables to run out and power the necessary electronics.
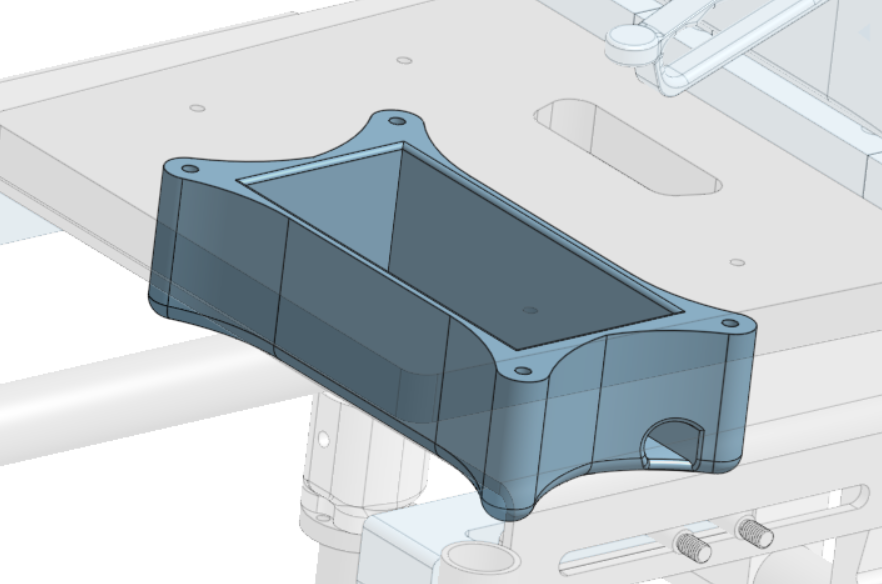
CAD of a translucent blue battery box with four corner mounting ears and a cable cutout, mounted under the seat plate.
04.6 — BATTERY BOXBattery Box
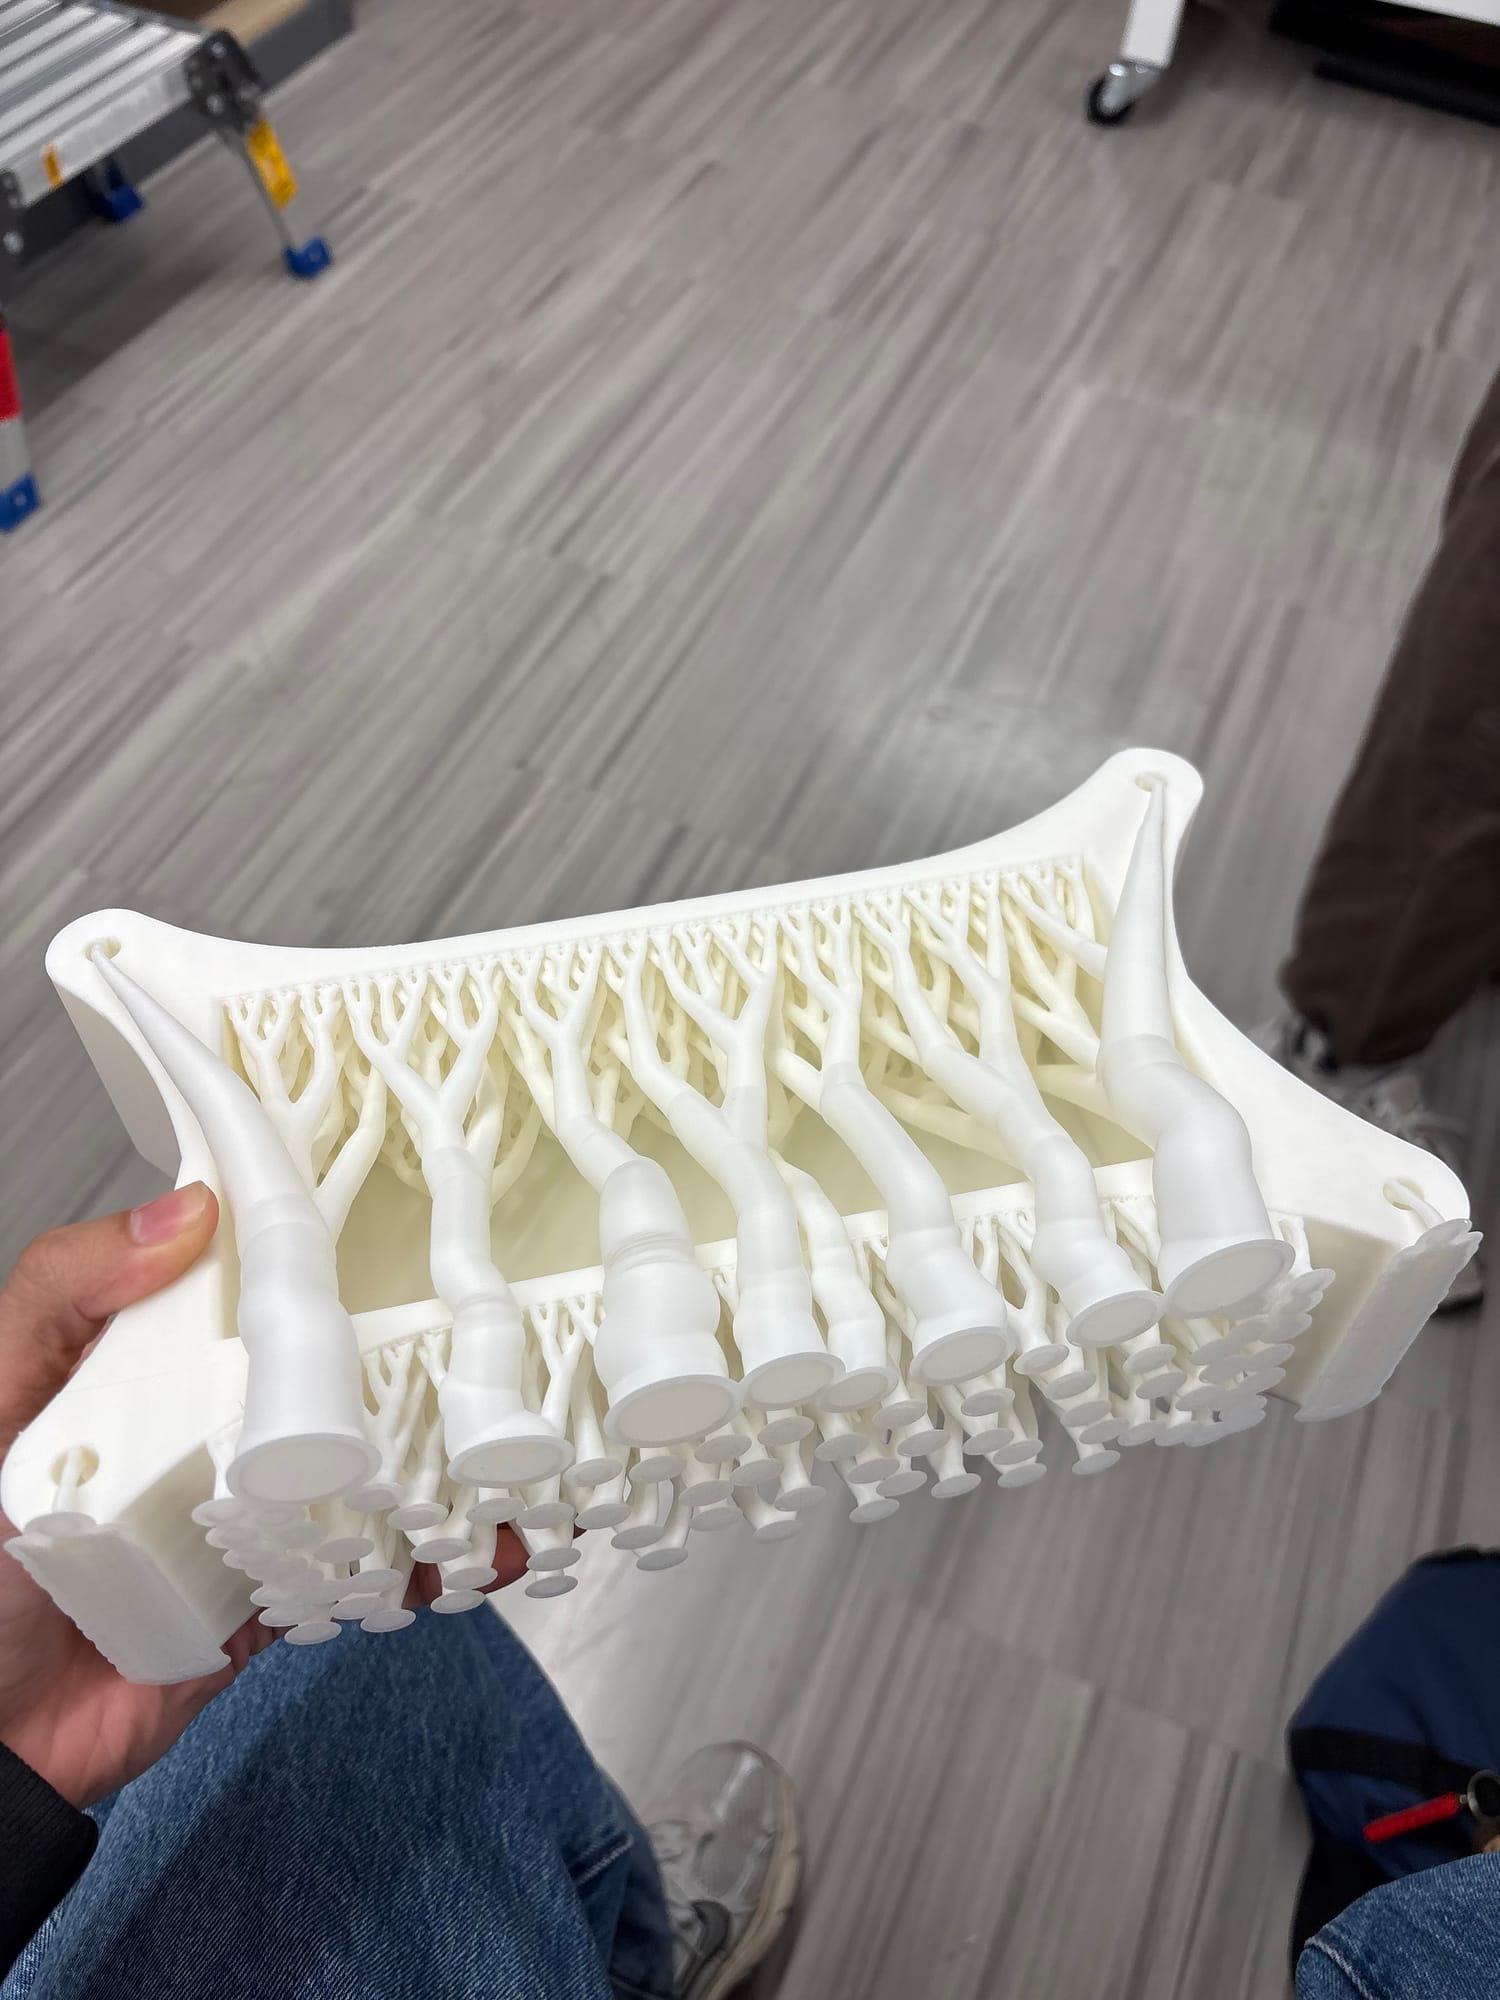
A hand holding a white printed housing upside down, its underside covered in branching tree supports.
04.7 — OFF THE PRINTERThe battery housing off the printer, tree supports still attached.
A blue battery pack seated in a white printed housing with corner mounting ears, its leads exiting through the end cutout.
04.8 — BATTERY FITTEDThe battery seated in its printed housing.

Let’s talk.

Open to co-op, internship and project conversations in mechanical design, product development and R&D.